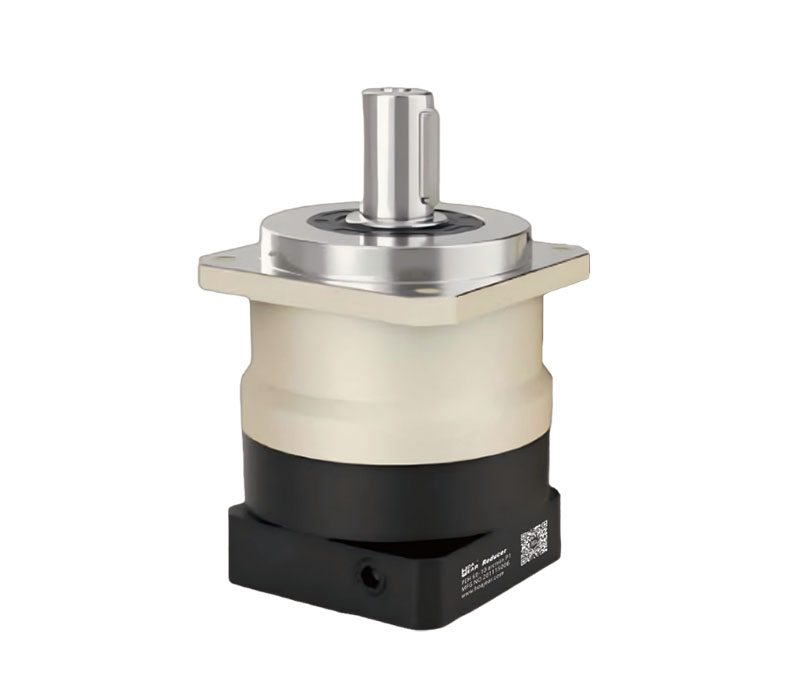
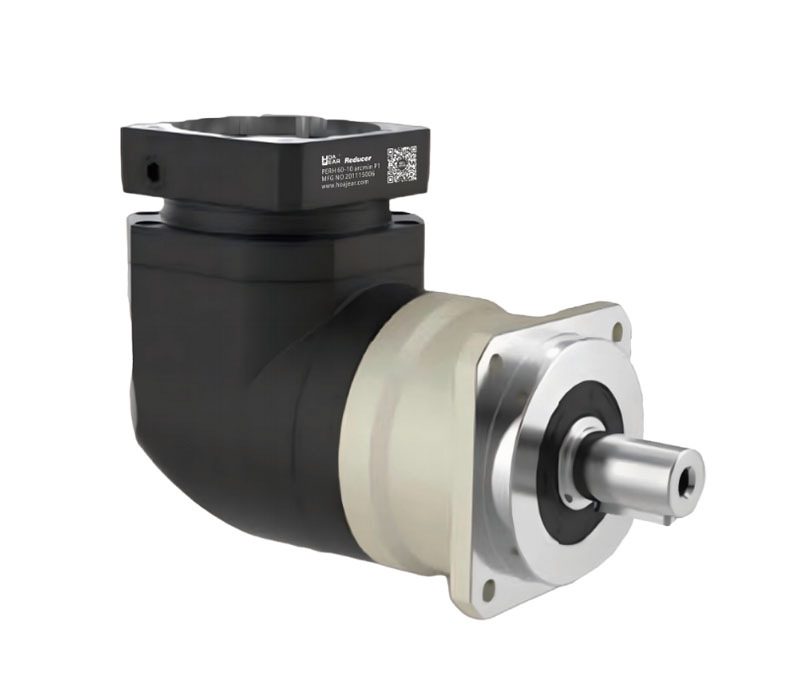
Correct Planetary Gear Reducer sizing connects the motor, transmission, and driven mechanism through a realistic operating cycle. Torque capacity alone cannot establish suitability. Speed limits, acceleration, load inertia, bearing forces, thermal conditions, and positioning requirements must also agree with the selected configuration.
A planetary gear reducer lowers output speed and increases available output torque, subject to efficiency and mechanical limits. It also changes the inertia seen by the motor. These effects can improve motor matching, but a larger reduction ratio is not automatically better.
The practical approach is to define the motion first, calculate loads consistently, and verify both motor and planetary gear reducer ratings. A planetary gear reducer should be selected for the application rather than matched only to motor power or flange size.
Begin with the required output motion. Record travel distance or rotation angle, maximum speed, acceleration time, deceleration time, dwell, and cycles per hour. A planetary gear reducer serving continuous conveying faces different demands from one driving rapid indexing.
Identify resisting forces, gravity, friction, and process torque throughout the cycle. Include empty and fully loaded conditions. A planetary gear reducer may encounter its highest acceleration torque with one payload and its highest sustained torque during another process step.
Document exceptional events separately, including controlled stops, jams, and emergency conditions. A planetary gear reducer rating for rare peaks must not be treated as permission to repeat the same load every production cycle.
Define reduction ratio as input speed divided by output speed:
i = n_input / n_output
For a planetary gear reducer with a 10:1 ratio, an output speed of 120 rpm requires 1,200 rpm at the input. Check the entire speed profile rather than only its average value.
A planetary gear reducer must remain within its permitted input and output speeds. Some specifications distinguish maximum speed from allowable continuous operation. Motor speed limits, torque curves, drive voltage, and application duty can impose additional restrictions.
Use available ratios as candidates rather than forcing a calculated value into the nearest option. Every candidate planetary gear reducer ratio changes motor speed, reflected inertia, acceleration requirements, and potentially stage count or transmission characteristics.
Steady load torque is the torque needed to overcome resistance at constant speed. For a tangential force acting at a radius:
T = F × r
Use newtons for force and meters for radius to obtain newton-meters. The output load on a planetary gear reducer may include several forces acting through different mechanisms.
For a conveyor roller, consider effective driving force and roller radius. For a vertical axis, account for gravity through the actual transmission. A planetary gear reducer driving a screw requires the screw lead, efficiency, and operating direction to convert linear force into torque.
Measure uncertain process resistance where practical. A planetary gear reducer selected from an optimistic friction estimate can become undersized when seals, guides, or product contact increase resistance.
Mass and rotational inertia are different quantities. Inertia depends on how mass is distributed around the axis. A planetary gear reducer rotating a wide fixture may need much more acceleration torque than one rotating an equally heavy compact fixture.
For a uniform solid disk rotating about its central axis:
J = 0.5 × m × r²
For a concentrated mass at distance r, use J = m × r². Combine the inertia of the fixture, workpieces, adapters, and other rotating components driven by the planetary gear reducer.
For complex assemblies, use validated CAD mass properties or an appropriate analytical model. Keep all inertia values referenced to the same shaft before combining them for planetary gear reducer sizing.
Acceleration torque equals rotational inertia multiplied by angular acceleration:
T_acceleration = J × α
Convert speed from rpm to radians per second using ω = 2πn / 60. For constant acceleration, α = Δω / Δt. The planetary gear reducer output must transmit the torque needed to accelerate the external rotating assembly.
Add resisting process torque with the appropriate sign. During forward acceleration against resistance, both demands usually add. During deceleration, gravity and process forces may assist or oppose stopping, changing the torque transmitted through the planetary gear reducer.
For jerk-limited profiles, use the actual peak acceleration rather than assuming the average represents the maximum. A planetary gear reducer must accommodate the resulting torque profile, including transition and reversal events.
The ideal load inertia reflected to the motor decreases with the square of the reduction ratio:
J_reflected = J_load / i²
For a planetary gear reducer with a 10:1 ratio, an output load inertia of 0.08 kg·m² reflects as 0.0008 kg·m² at the motor shaft. This is a kinematic relationship, not a complete loss model.
Add gearbox input-referenced inertia and coupling inertia when evaluating the motor load. A planetary gear reducer contributes its own rotating inertia, which can vary with size, ratio, and construction.
Define inertia ratio consistently, commonly as external inertia referred to the motor divided by motor rotor inertia. There is no universal acceptable ratio for every planetary gear reducer and servo system; control capability and mechanical dynamics matter.
During forward motoring, a useful approximate relationship is:
T_motor ≈ T_output / (i × η) + J_input × α_motor
Here, J_input includes motor rotor inertia and other input-referenced rotating inertia not already included in T_output. A planetary gear reducer calculation must avoid counting the same inertia twice.
If output torque already includes load acceleration, do not add that reflected load acceleration again as a separate motor demand. Use a consistent accounting method throughout the planetary gear reducer model.
Efficiency depends on operating conditions. A single assumed value can support an initial estimate, but low-load losses and reverse power flow may require a more detailed model. Final planetary gear reducer selection should use suitable loss data and drive calculations.
Consider a horizontal rotary fixture with 0.08 kg·m² output inertia, 3 Nm resisting torque, and a target speed of 120 rpm reached in 0.20 seconds with constant acceleration. Evaluate a planetary gear reducer with a 10:1 ratio and an illustrative 95% efficiency.
Output angular speed is approximately 12.57 rad/s. Acceleration is therefore 62.83 rad/s², producing 5.03 Nm acceleration torque. Adding process resistance gives approximately 8.03 Nm output torque during acceleration.
The planetary gear reducer input reaches 1,200 rpm, with motor acceleration of 628.32 rad/s². Assume motor rotor inertia of 0.00020 kg·m² and gearbox input inertia of 0.00005 kg·m², with negligible additional coupling inertia.
| Calculated quantity | Illustrative result |
|---|---|
| Output acceleration torque | 5.03 Nm |
| Output torque during acceleration | 8.03 Nm |
| Motor speed at target output speed | 1,200 rpm |
| Output-demand contribution to motor torque | 8.03 / (10 × 0.95) ≈ 0.845 Nm |
| Motor and gearbox input inertia torque | 0.00025 × 628.32 ≈ 0.157 Nm |
| Estimated motor acceleration torque | Approximately 1.00 Nm |
| External-to-rotor inertia ratio | (0.0008 + 0.00005) / 0.00020 = 4.25 |
These calculations do not establish a final rating. The planetary gear reducer still needs torque, speed, duty, bearing, thermal, and stopping checks. The motor must provide the required torque at the corresponding speed.
Compare the calculated output torque profile with the exact definitions in the product documentation. A planetary gear reducer may list nominal torque, acceleration torque, cyclic torque, and emergency-stop torque under different conditions.
Peak duration and permitted frequency matter. An emergency rating may apply only to a limited number of events. A planetary gear reducer operating within that numerical torque value can still be unsuitable for repetitive indexing.
Check both positive and negative torque where the motion reverses or regenerates. A planetary gear reducer should also be assessed for lifetime loading rather than only the largest event. Apply the specified fatigue or equivalent-load method instead of substituting an unrelated averaging formula.
For discrete segments, motor RMS torque is commonly estimated as:
T_RMS = √[Σ(T_k² × t_k) / Σt_k]
Include acceleration, travel, deceleration, and dwell torque over the complete cycle. A planetary gear reducer changes motor demand, so repeat this calculation when comparing ratios or motor sizes.
RMS torque is useful for motor thermal evaluation, subject to the motor's cooling and speed-dependent capabilities. It is not automatically the correct fatigue-sizing method for planetary gear reducer teeth or bearings.
Check planetary gear reducer thermal capacity separately using the required operating conditions. A planetary gear reducer inside a hot enclosure may have less effective heat dissipation than one mounted on an exposed conductive structure. Verify lubricant and housing temperature limits as well.
A planetary gear reducer can satisfy torque requirements while failing its external-load check. Belt tension, sprocket forces, pinion contact, and fixture weight can impose radial loads, axial loads, and bending moments.
Record where each force acts relative to the output support. A longer overhang increases bending moment even when transmitted torque remains unchanged. The planetary gear reducer shaft diameter alone does not establish allowable bearing loading.
Compare the actual combination of forces with the specified rating method, including speed and required bearing life. Where necessary, support the driven mechanism separately. Ensure that added supports do not misalign or overconstrain the planetary gear reducer output connection.
Positioning requirements can determine the configuration after torque and speed checks pass. A planetary gear reducer introduces backlash, elastic twist, and transmission error, each of which can influence the driven mechanism differently.
Specify acceptable motion at the working point. Angular movement becomes linear displacement at a fixture radius, so a small angular error can matter on a large table. A planetary gear reducer used for frequent reversals deserves particular attention to lost motion.
Lower backlash does not guarantee high stiffness or fast settling. Evaluate motor feedback location, coupling compliance, structural behavior, and control tuning together. A planetary gear reducer should meet the complete positioning requirement under representative load and temperature conditions.
Increasing ratio reduces reflected load inertia and the motor torque contribution from output demand. However, it increases motor speed and acceleration for the same output motion. A planetary gear reducer with additional stages may also change efficiency, inertia, backlash, and dimensions.
Compare several feasible combinations using identical motion data. Include motor torque curves, gearbox ratings, thermal performance, positioning, and installation space. A planetary gear reducer with the smallest frame is not necessarily the most economical complete solution.
Use margins that reflect documented uncertainty and required service conditions. Avoid applying several overlapping factors without understanding their purpose, since excessive oversizing can increase inertia, cost, and integration effort.
Deceleration can return energy through the transmission to the motor and drive. Calculate the energy associated with moving components and check the drive's regenerative capacity or braking arrangement. A planetary gear reducer must also tolerate the resulting torque and the specified stopping frequency.
Holding a stationary gravity load is a separate requirement from slowing a moving mechanism. Do not assume that a planetary gear reducer prevents backdriving after power loss. Specify an appropriate brake or restraint where required, and distinguish its holding capability from any permission to absorb repeated dynamic stops.
No. Planetary gear reducer selection cannot rely on power alone, which does not define acceleration peaks, external bearing loads, or positioning behavior. Use the complete torque-speed cycle and the required service conditions.
No. It reduces reflected inertia but increases motor speed and acceleration. Compare complete motor and transmission performance for the required output motion.
No. Use RMS torque where appropriate for motor heating, and follow the gearbox's specified methods for repetitive loading, fatigue, speed, and thermal capacity.
Provide load inertia, process torque, speed profile, duty cycle, external shaft forces, accuracy requirements, environment, mounting arrangement, and motor data. Include unusual stops and future process changes that affect loading.
QR Code

почтовый ящик

Этот веб-сайт использует файлы cookie, чтобы обеспечить вам максимально эффективное использование нашего веб-сайта.


 EN
 Español
 Indonesia
 Tiếng Việt


 WhatsApp
 телефон
 почтовый ящик
 сообщение
Комментарий
(0)